
Back to the 2024 paper
Similar questions
Robotics Control System Consider a closed-loop system with an open-loop transfer function G(s)H(s) = \frac{10(s + 0.5)}{s^2(s + 2)(s + 10)} Apply the Nyquist stability criterion to determine the closed-loop stability of the system.202414m Robotics Control System Consider the mechanical system shown in the figure below. Find the transfer function G(s) = \frac{V_1(s)}{F(s)} 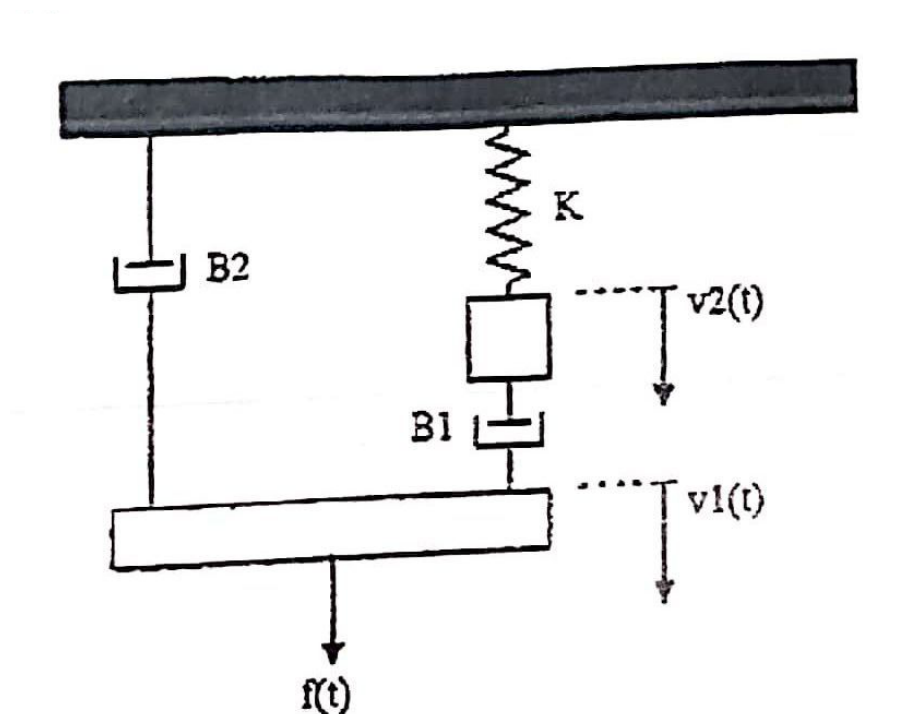20247m Robotics Control System The block diagram of a simple servo system is shown below 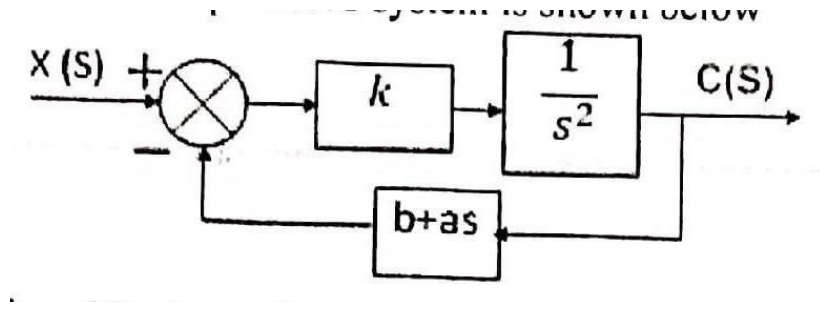 (i) If k = 10, determine the values of 'a' and 'b' to give an overshoot of 16\% and a time constant of 0.1 sec to a unit step input. (ii) Determine t_r, t_p, \omega_d and t_{ss} if k = 40.20247m Robotics Control System Draw the root locus for G(s)H(s) = \frac{k}{s(s^2 + 2s + 5)} and find the range of 'k' for stability.20247m
PreviousThe SFG of a control system is shown in the figure below. Find the transfer function C/R. 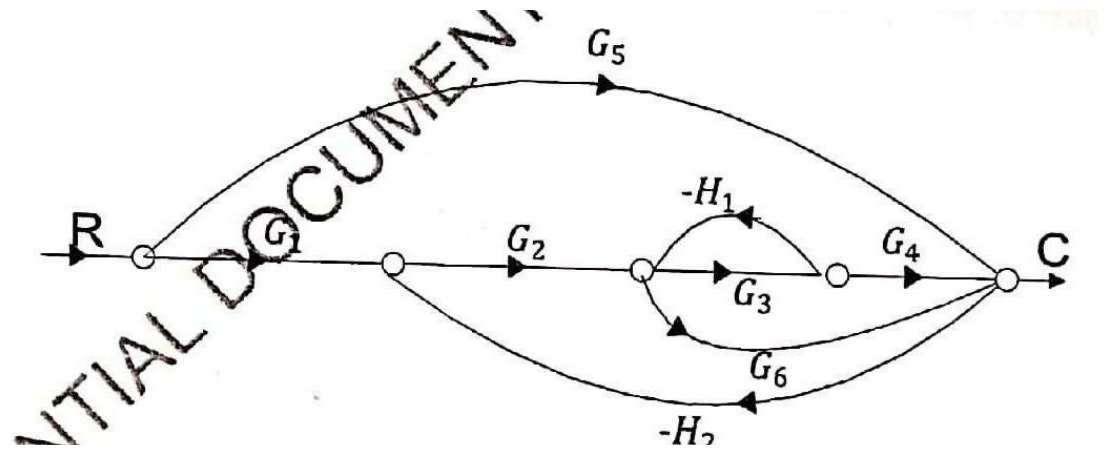NextExplain how relays, switches, and contactors are used in implementing simple and sequential control systems. Provide a schematic example of a motor control circuit.
Student FinanceWeb Platform
Pocketly — Personal Finance for Students
Keep your hostel and college expenses under control. Track accounts, log spending in seconds, and stay within your monthly budget.